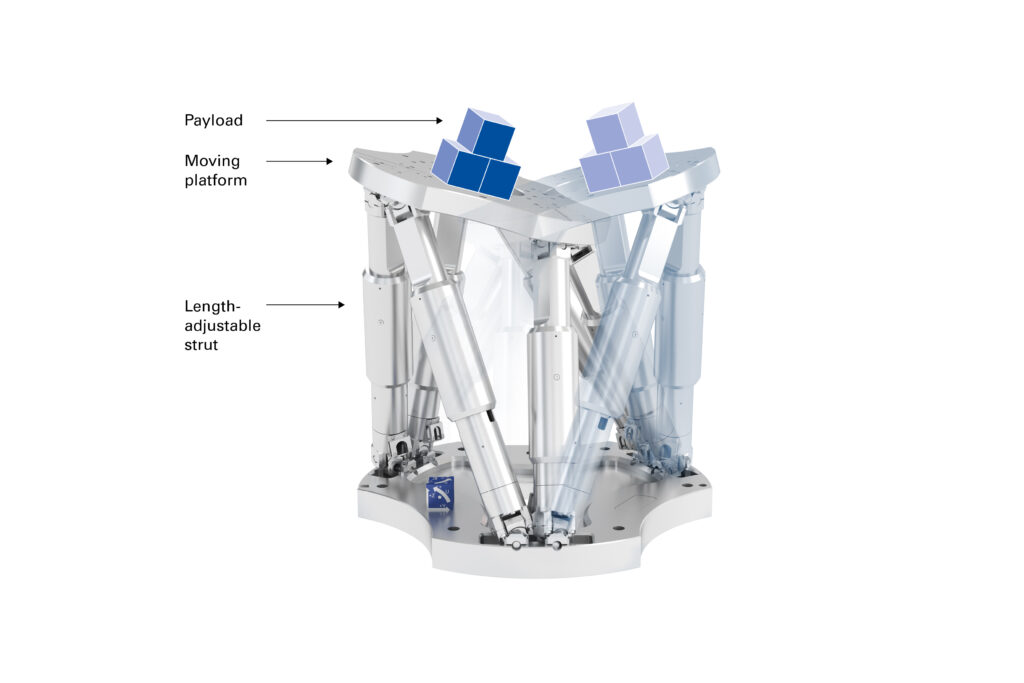
Improving hexapod positioning performance through compensation for mechanical compliance in parallel kinematics
In hexapods using six length-adjustable struts for positioning an end-effector, the compliance (or inversely, the stiffness) of individual components or structures, such as these struts, is an important performance determining...
In hexapods using six length-adjustable struts for positioning an end-effector, the compliance (or inversely, the stiffness) of individual components or structures, such as these struts, is an important performance determining factor. With increasing load of the hexapod, increasing position deviations are observed for the end-effector. A control engineering approach has been developed and tested, as described in this Mikroniek article, using a model-based calculation method (stiffness model) to compensate for the compliance and thus reduce the position deviation. Improvements by a factor of 10 to 20 have been demonstrated.