EVENT 4 July 2022
Lunch Lecture September hosted by TU/e
Mechatronic systems have increasingly high performance requirements for motion control.
About this event
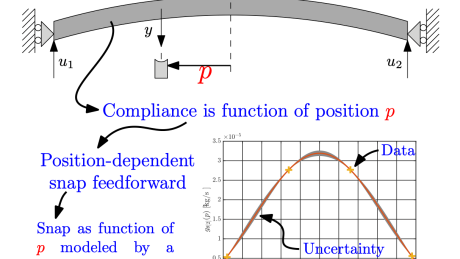
Position-Dependent Snap Feedforward: A Gaussian Process Framework
The low-frequency contribution of the flexible dynamics, i.e. the compliance, should be compensated for by means of snap feedforward to achieve high accuracy. Position-dependent compliance, which often occurs in motion systems, requires the snap feedforward parameter to be modeled as a function of position. Position-dependent compliance is compensated for by using a Gaussian process to model the snap feedforward parameter as a continuous function of position. A simulation of a flexible beam shows significant performance increase when using the Gaussian process snap feedforward parameter to compensate for position-dependent compliance.
The speaker will be: Maurice Poot, PhD Candidate at Eindhoven University of Technology
We will start at 12:02pm on September 5 2022
Please send an email to info@dspe.nl if you are interested in this Lunch lecture.
The Netherlands
DigitalReferences ...
Knowledge day: “AI & (mechanical) Design”
Learn how AI in Engineering develops at ASML, Sioux and TU/e
Read more
Wim van der Hoek’s Design Principles – Applying and Extending his Legacy
During the 2026 Precision Fair in Den Bosch (NL) on Thursday, November 19, 14:00-16:10h, DSPE will host the “Wim van der Hoek’s Design Principles – Applying and Extending his Legacy” colloquium.
Read more
DSPE Opto-Mechatronics Symposium 2026
The seventh edition of the DSPE Opto-Mechatronics Symposium will take place on 8 October 2026. This year’s theme is ‘The opto-mechatronics of telescopes: from tiny to extremely large’.
Read more