Lunch Lecture September hosted by MI – Partners
Title: Observer-based modal control for over-actuated precision motion systems. Join this lecture digital on September 21 2026
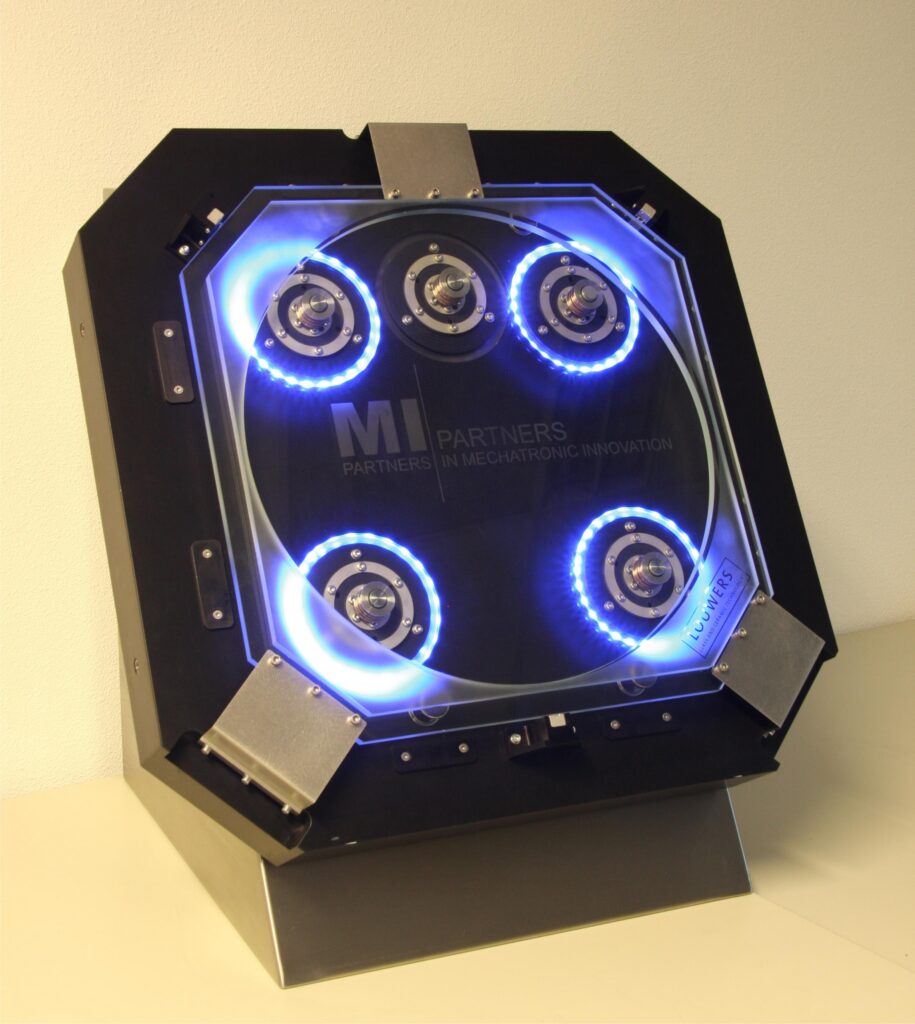
High-precision motion systems are increasingly constrained by lightly damped flexible dynamics, limiting both accuracy and throughput. This talk presents an observer-based approach for actively damping these dynamics in over-actuated systems. A frequency-domain identification method estimates natural frequencies, damping ratios, and mode shapes from measured data. These identified modal parameters are subsequently used to tune both the observer and the active damping controller, allowing the Kalman filter to be designed for a prescribed level of modal damping rather than being tuned based on noise statistics. The active damping controller is designed to minimize interaction to the rigid-body control loop. Experimental results obtained on an over-actuated setup demonstrate a significant reduction in standstill positioning error, while increasing the achievable control bandwidth.
Speaker: Max Jans, MI-Partners, Technologist Dynamics & Control
Company: MI – Partners
Date: September 21 2026
Time: 12:02pm
Location: Teams
Please send an email to info@dspe.nl if you are interested in following this lecture.