EVENT 15 June 2026
Lunch Lecture September hosted by MI – Partners
Title: Observer-based modal control for over-actuated precision motion systems
About this event
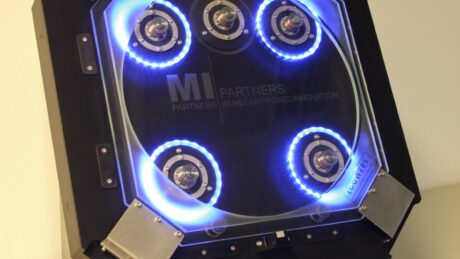
High-precision motion systems are increasingly constrained by lightly damped flexible dynamics, limiting both accuracy and throughput. This talk presents an observer-based approach for actively damping these dynamics in over-actuated systems. A frequency-domain identification method estimates natural frequencies, damping ratios, and mode shapes from measured data. These identified modal parameters are subsequently used to tune both the observer and the active damping controller, allowing the Kalman filter to be designed for a prescribed level of modal damping rather than being tuned based on noise statistics. The active damping controller is designed to minimize interaction to the rigid-body control loop. Experimental results obtained on an over-actuated setup demonstrate a significant reduction in standstill positioning error, while increasing the achievable control bandwidth.
Speaker: Max Jans, MI-Partners, Technologist Dynamics & Control
Company: MI – Partners
Date: September 21 2026
Time: 12:02pm
Location: Teams
Please send an email to info@dspe.nl if you are interested in following this lecture.
The Netherlands
DigitalReferences ...
Wim van der Hoek Award celebrates 20th anniversary
The Wim van het Hoek award (also known as the Constructors Award) was introduced in 2006 to mark the 80th birthday of the Dutch doyen of design engineering principles, Wim van der Hoek (1924-2019).
Read more
National Systems Engineering Event Calendar
A single overview of the major Systems Engineering events in the Netherlands
Read more
Knowledge day: “AI & (mechanical) Design”
Learn how AI in Engineering develops at ASML, Sioux and TU/e. On november 5th DSPE organizes a knowledge day to intend to inform the DSPE members about the (im-) possibilities of applying AI in mechanical- and system design
Read more